How do precise motor programs generalize for robust behaviors?

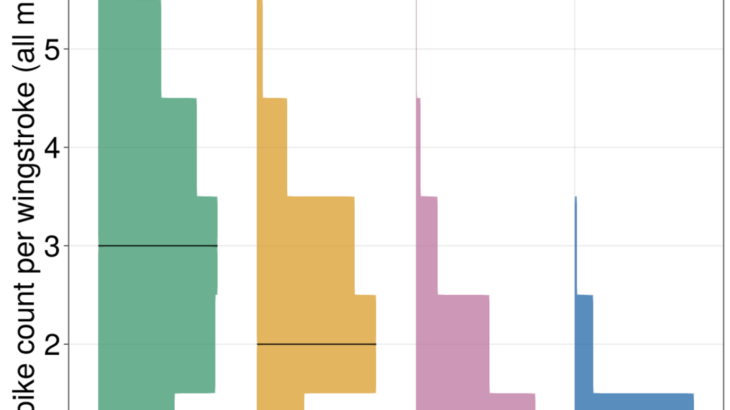
Locomotor systems need the ability to maintain performance during a wide range of mechanical demands. Large fluctuations in body mass due to growth, injury, or feeding prove to be an important example of such demands. Foraging Manduca sexta can increase their body mass by approximately 50% in a short period of hovering feeding while still […]

Continue reading How do precise motor programs generalize for robust behaviors?
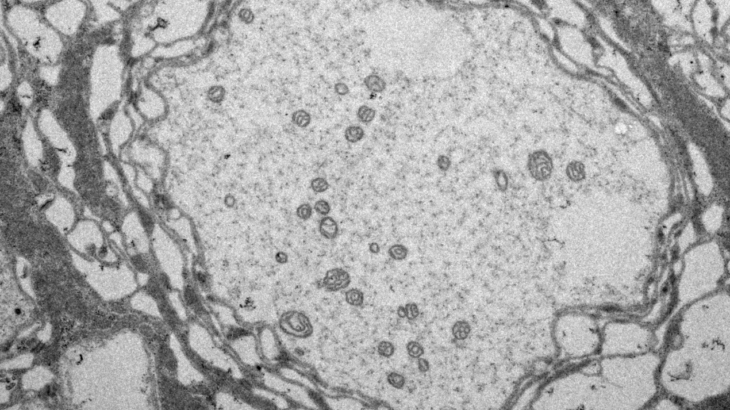

Conduction of Signals in the Hawkmoth

The ability to quickly maneuver through a variety of environments requires a central nervous system that can rapidly transfer sensory and motor signals. The neck connective, a bottleneck in the information traveling from the brain to the thorax, is being sectioned and imaged using transmission electron microscopy. These incredibly high resolution images show that, among […]

Continue reading Conduction of Signals in the Hawkmoth


Flight motor programs across species: Are faster-flapping insects more precise?

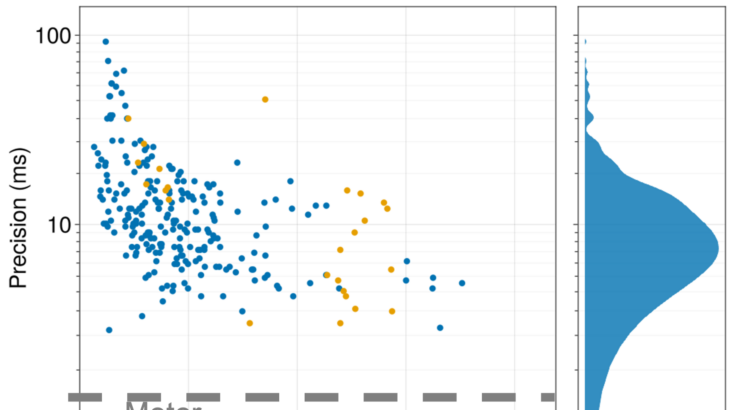
Wingbeat frequency in flying insects spans several orders of magnitude; Even just in bombycoid moths, wingbeat frequency can vary from 5 Hz all the way up to 80 Hz or even more. All of these moth species have to accomplish these very different frequencies of locomotion using highly conserved flight musculature and neural constraints, so we wanted […]

Continue reading Flight motor programs across species: Are faster-flapping insects more precise?


Comparison of synchronous and asynchronous actuation strategies in response to perturbations

There are two regimes for actuating flapping wings known as synchronous and asynchronous. Synchronous flapping is where each wing beat corresponds to a muscle contraction caused by a neural signal resulting in the wing beat frequency matching the neural excitation frequency. In contrast, the asynchronous regime’s wing beat frequency is decoupled from the neural activation […]

Continue reading Comparison of synchronous and asynchronous actuation strategies in response to perturbations


Fast Reference-Locking in Hover Feeding Hawkmoths

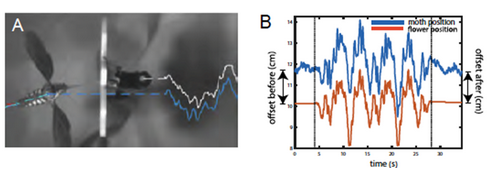
Tracking and stabilization involves control around a fixed point. Depending on the method of control, this may or may not require memory in the form of a reference-point. While insects perform a wide range of memory-based behaviors, the fast formation and forgetting of reference points for control, has not been described before. We observed kinematics […]

Continue reading Fast Reference-Locking in Hover Feeding Hawkmoths


Performance advantages of centralized neuromechanical control over variable terrain

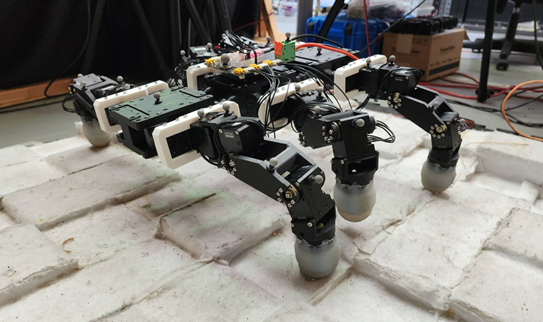
Centralization which measures the coupling between neuromechanical modules that mediate responses to perturbations, has been determined to be an important parameter in locomotion for both biologists and roboticists. This metric can help capture how the various subsystems within an organism are interacting to produce an observed behaviour such as navigating across complex terrain. Our work […]

Continue reading Performance advantages of centralized neuromechanical control over variable terrain


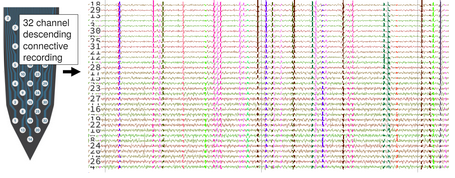
Task-Relevant Descending Information in the Neck Connective

The neck connective in insects connects the brain to the thoracic motor control centers. This is a bottleneck in information-flow, through which all movement-relevant information from the brain must pass through. In the context of flower-tracking behavior, we ask whether the behaviorally observed features of multisensory control may be inferred from descending information in the […]

Continue reading Task-Relevant Descending Information in the Neck Connective


Variation of Centralization with Terrain Complexity and Locomotion Speed

Locomotion emerges due to interactions between various subsystems such as sensory systems for vision. Rather than analyzing all the subsystems in detail which would be very complex, we use a metric that captures some property of the interactions between them. Our chosen metric is centralization which measures the coupling between neuromechanical modules that mediate responses […]

Continue reading Variation of Centralization with Terrain Complexity and Locomotion Speed


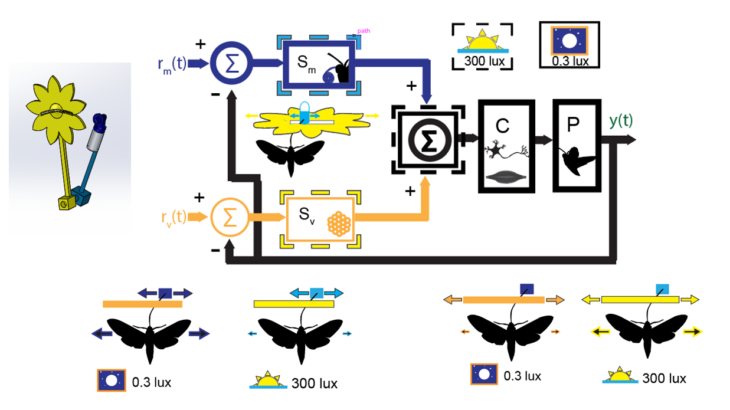
Multisensory Integration is Luminance-Dependent

Hawkmoths such as Manduca sexta use proboscis mechanosensation as well as vision to track moving flowers while hover-feeding. In crepuscular moths, this poses a challenge since vision depends heavily on background luminance. If mechanosensory motor-response does not compensate, the same multisensory control can reduce flight performance. Using a two-part robotic flower to provide conflicting sensory […]

Continue reading Multisensory Integration is Luminance-Dependent